2025-2026 Season
FTC Game: DECODE
Robot: Something II
Team Overview
Standard Deviation, from Eden Prairie, Minnesota, competed in the DECODE season with six students from the International School of Minnesota: Jason, Roshan, Ryan, Asif, Ean, and Alex. Jason was a senior, Ryan a junior, and the other four students were sophomores.
- Team composition: 1 senior, 1 junior, and 4 sophomores
- Team members: Jason, Roshan, Ryan, Asif, Ean, and Alex
- Mentor support: 1 lead mentor with industry engineering experience
Mission
Our mission is to improve ourselves and our community through outreach, STEM learning, and inspiring younger students to explore robotics and engineering.
Future Goals
- Strengthen team skills, especially CAD and building
- Increase outreach hours
- Improve event performance
- Build stronger connections with lower school robotics programs
Robot Overview
3D CAD viewer is disabled. Enable it in _config.yml
For DECODE, we chose a mecanum-drive robot with a custom drivetrain to maximize scoring potential through fast alignment and flexible movement.
Chassis Design
- Custom 1/8 inch 5052 aluminum plates manufactured by SendCutSend
- Seven motors mounted between inner and outer side panels
- Pocketed plates reduce weight and add wire-management points
- Drag chain protects turret wiring during motion
- Integrated battery door supports fast battery swaps
Intake and Deposit System
Our intake/deposit design has gone through six major iterations:
- Dual flywheel with fins and 2-axis wrist
- Internalized wrist and polycarbonate backplate
- Flat flywheel and adjustable hood
- Rear flywheel removed
- Fixed hood (good long-range consistency, weaker close-range flexibility)
- Planned return to adjustable hood for broader shot utility
Lift System
We developed six major scissor-lift-based iterations:
- Initial flat-beam scissor lift was too weak
- Reinforced beams improved strength but reduced max height
- Added beams restored height but risked separation
- Added bottom plate to prevent separation
- Custom coupler fixed torque slippage in the drive path
- Final redesign tested a worm-gear flipper, but tooth engagement and axial support were insufficient
Indexer
Five major indexer iterations:
- Dual-path servo-controlled feed (unreliable)
- Carousel with mini mecanums (too large, too many motors)
- Carousel plus funnel plus Geneva mechanism (worked but lacked independent control)
- Axon-servo-powered carousel (best performer so far)
- Planned servo-kicker tray concept (jam risk under evaluation)
Kicker
Four major improvements:
- Shortened kicker to reduce torque demand
- Added software interlock to prevent empty actuation
- Added rigid servo mount
- Switched to metal geartrain to eliminate stripping
CAD and Fabrication
- CAD platform: Onshape with modular design philosophy
- Material and process: PETG-CF 3D-printed components for rapid iteration
- Printer fleet: Bambu P1S, Bambu X1C, Prusa MK3S+, Anycubic Vyper
Autonomous Capabilities
From any starting location, our autonomous can score LEAVE points and artifacts, while adapting routes around alliance partners.
Minimum Goal
- Score LEAVE points in autonomous
- Score some artifacts
- Achieve a partial park
Maximum Goal
- Score 3 artifacts in autonomous
- Score consistently in teleop
- Complete full plus partial return-to-base actions in endgame
Design Process
Our software and mechanism workflow follows:
Identify -> Ideate -> Design -> Create -> Test
This process was adopted from former team Catlateral Damage.
Driver Controls
Driver Controls
- Three driver-control layers through trigger-based controller mapping
- Speed toggle for precision alignment
- Macros for flywheel, intake, and turret workflows
- Manual override always available
- Color-sensor-aware macros to reduce cycle mistakes
- Automatic aiming and dynamic shot-power calculations
Autonomous
- Reliable LEAVE and artifact-scoring flow from all starting locations
- Pathing adjusts based on alliance partner movement and positioning
The Team
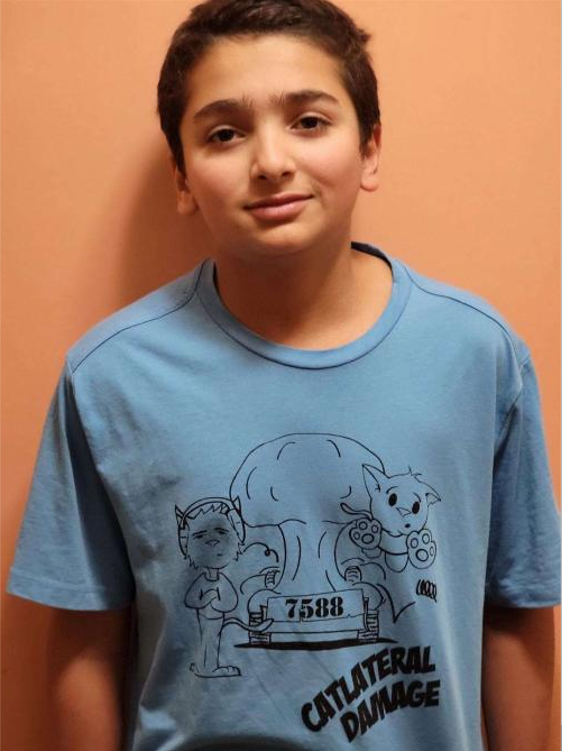
Roshan
CAD, Build, Programming
Grade 10
A sophomore at the International School of Minnesota. This is his fifth year in FTC. Roshan works across CAD, building, and programming. He enjoys swimming, and his favorite subject is math.
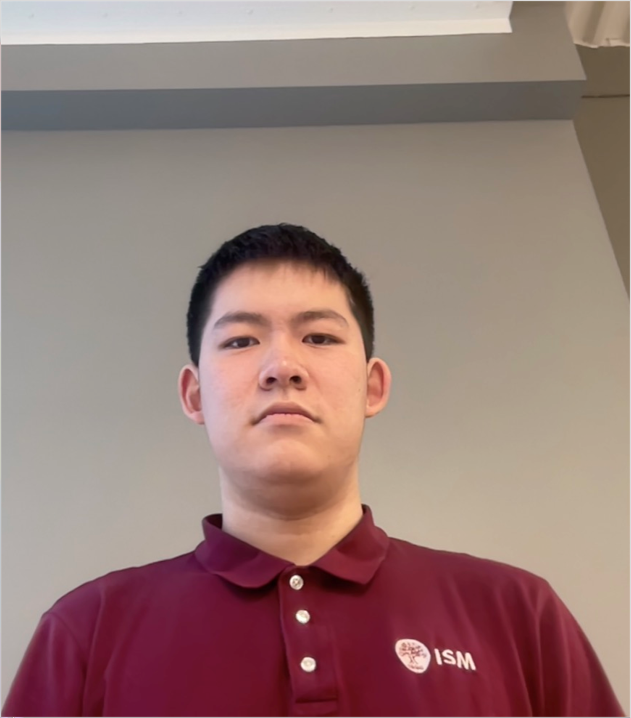
Jason
Building & Driver
Grade 12
A senior at the International School of Minnesota. This is his third year in FTC. Jason focused on building and driving, and he enjoyed anime and physics.
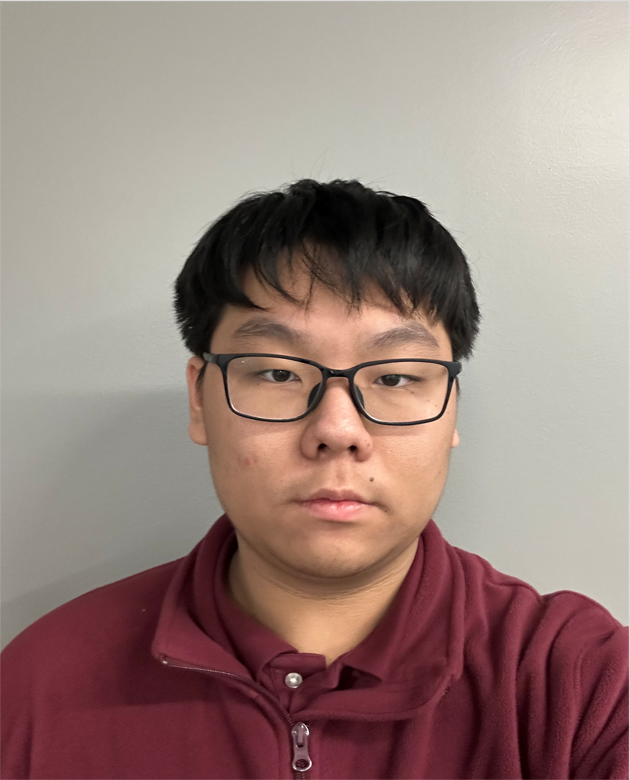
Ryan
Building, Programming, Driver
Grade 11
A junior at the International School of Minnesota. This is his fourth year in FTC. Ryan works across building, programming, and driving. He enjoys music, and his favorite subject is biology.
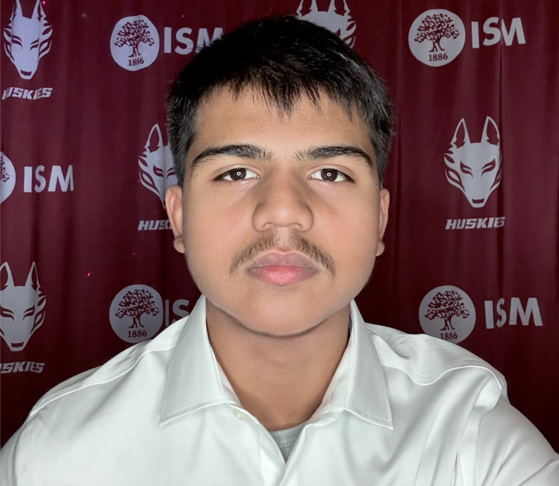
Asif
Build
Grade 10
A sophomore at the International School of Minnesota. This is his first year in FTC. Asif focuses on building, enjoys badminton, and his favorite subject is math.
Ean
Build
Grade 10
A sophomore at the International School of Minnesota. This is his first year in FTC. Ean focuses on building, and he enjoys volleyball and tennis.
Alex
Build
Grade 10
A sophomore at the International School of Minnesota. This is his first year in FTC. Alex focuses on building and enjoys sports, physics, and math.
Outreach
Our outreach strategy emphasizes motivating new students, connecting with industry mentors, and sharing practical engineering lessons.
Motivate
Valentine’s Bot Event
We built a gifting robot that delivered chocolates and 3D-printed gifts around campus, engaging hundreds of students.
International Day Robotics Exhibition
We hosted a dedicated robotics room, demonstrated our robot, shared our notebook process, and ran hands-on STEM activities to recruit and inspire students.
City Park Demonstration
We showcased our robot in a public park, giving visitors a chance to drive it and learn FTC systems.
Connect
Problem and Solution: Lift Mechanism Failure
Our original endgame lift used a three-gear train and coupler to drive a lead screw, but the coupler failed to transfer torque consistently. After repeated tuning attempts, the mechanism remained unreliable.
Esmeril Industries Trip
Parents in industrial manufacturing invited us for a factory tour, reviewed our lift architecture, and helped us design a custom coupler that resolved the torque-transfer issue.
Team Sustainability
We prioritize long-term continuity by combining low-cost fabrication methods with active annual recruitment.
- 3D printing and laser cutting reduce part costs and speed replacement cycles
- Recruiting new students yearly preserves knowledge transfer and team continuity
Competition Results
Our recorded season awards were:
- Think Award, 2nd Place at MN FTC Otsego Saturday
- Control Award at Maple Grove Saturday Qualifier
Gallery
Coming Soon - Check Back Later.